
'A flight should not come at the expense of someone’s back'
UNSEQ brings Physical AI into aircraft baggage holds: "AI development creates opportunities to solve problems that have long been difficult"
Published on October 24, 2026
UNSEQ
Bart, co-founder of Media52 and Professor of Journalism oversees IO+, events, and Laio. A journalist at heart, he keeps writing as many stories as possible.
Ahead of the AI Pitch Competition finals on 12 November at the Evoluon in Eindhoven, IO+ continues its deep-dive series profiling the eight finalists and one wildcard. In this eighth instalment, Robert de Bruijne, co-founder and CEO of UNSEQ, discusses how Vision-Language-Action models and World Action Models are moving robotics into the narrow holds of aircraft, relieving workers of dangerous manual labour while keeping tight turnaround schedules intact.
Inside the narrow belly of a passenger aeroplane, the conditions are punishing. Loading and unloading baggage is cramped, physically exhausting, and performed under constant time pressure in a space where handlers cannot even stand upright. In a single turnaround, a ground handler might lift up to 180 bags, some weighing as much as 32 kilograms, repeating the sequence several times a day in poor air quality.
As passenger numbers keep growing, airports worldwide face chronic staffing shortages and high tarmac turnover. Yet conventional factory automation can't work inside an aircraft hold: every piece of luggage is different, an overstuffed duffel bag flexes unpredictably compared to a rigid polycarbonate case, and manoeuvring room is measured in centimetres.
Eindhoven-based startup UNSEQ is taking on this challenge. By pairing Vision-Language-Action (VLA) models with World Action Models and reinforcement learning, the team is building autonomous physical AI capable of handling deformable, chaotic objects in tight spaces.
Co-founder and CEO Robert de Bruijne explains why physical AI must move from flashy demos to shift-long reliability, how they approach European safety regulations, and why taking the heavy burden off human shoulders is a mission worth solving.
Vision-Language-Action models meet the aircraft hold
"At UNSEQ, we develop robots for one of the toughest jobs in aviation: loading and unloading baggage inside aircraft holds," De Bruijne explains. "It is cramped, physically demanding work, with very little space to manoeuvre. Every bag is different, and a soft sports bag behaves very differently from a hard-shell suitcase."
Traditional industrial robotics relies on structured, predictable factory environments. To handle the unpredictability of a baggage stack, UNSEQ turns to the latest frontier in physical AI: "AI is at the core of our approach to handling that variation," says De Bruijne. "We use Vision-Language-Action, or VLA, models, which build on advances in language and vision models to connect what the robot sees and the task it is given to physical actions. We combine these models with insights from reinforcement learning and World Action Models (WAMs) to improve how the robot selects actions and anticipates their effects."
The engineering hurdle is getting those capabilities to run deterministically on the ramp: "The challenge is making this combination work reliably inside the hold. The robot needs to recognise the baggage, determine how to grasp it, and plan its movements within the available space. Our focus is developing and adapting these AI methods to the unpredictable conditions of baggage handling, where conventional automation struggles."
A global market starting from a standardised space
While the operating conditions are demanding, narrow-body aircraft holds present a focused, globally standardised operational environment. "The aircraft hold gives us a focused starting point with an international market," De Bruijne points out. "Ground handlers at airports around the world face similar challenges with heavy lifting, staffing, and tight turnaround schedules."
Expanding the technology requires industrial-grade execution beyond the software layer: "Our aim is to develop a repeatable system that fits into their operations. Scaling it will require manufacturing, maintenance, operator training, and reliable support. We also need to demonstrate that it can handle different baggage and operating conditions safely, throughout a working day."
Mastering the hold will also serve as a technological springboard: "Once we have established that capability, the AI technology we develop will also be useful in other robotics applications involving varied objects and confined spaces. But the first milestone is very concrete: a dependable system for loading and unloading aircraft holds."
Responsible physical AI and edge-case testing
Because UNSEQ’s models interact with physical cargo rather than profiling individuals, conventional algorithmic bias appears in a very different light. "Our robot makes decisions about how to handle baggage, so questions around bias and fairness arise differently from AI systems that assess people," De Bruijne notes. "The immediate requirement is to handle the variety of bags it encounters reliably."
Avoiding operational failures means rejecting sanitised lab assumptions: "Testing only on neatly positioned suitcases could give a misleading impression of performance. Inside a hold, bags can be soft, worn, awkwardly shaped, or partly hidden. Representative testing and clear operating limits help address that risk."
Equally critical is worker inclusion: "Responsible AI still matters, particularly for the people working around the equipment. They need to understand its capabilities, recognise its limits, and know how to intervene. We also need to involve baggage handlers in the transition. Their experience is valuable for developing AI that responds to real working conditions and understanding how the AI-powered system will change their work."
Relieving human bodies from punishing labour
For De Bruijne, the societal case for robotics on the tarmac is grounded in occupational health."Imagine handling 180 bags during an aircraft turnaround, with some weighing as much as 32 kilograms," he illustrates. "Then doing that several times a day, in a space where you cannot stand upright. Over a working life, that strain adds up. Air quality around aircraft adds another concern. We believe people should not have to spend their careers working under those conditions. A flight should not come at the expense of someone's back."
Automation offers a way to ease operational bottlenecks while protecting staff: "People want to keep flying, and ground handlers face persistent difficulties recruiting and retaining staff. We expect that pressure to continue. Automating the heaviest work could help keep operations running while improving working conditions."
The workflow preserves human responsibility: "That transition needs care. Our intended approach keeps a human operator or supervisor involved outside the aircraft, with training and clear responsibilities."
Avoiding distraction: Grounding deep tech in physical realities
Translating embodied AI into harsh operational environments requires resisting academic hype and keeping engineers close to the tarmac. "One of the biggest challenges has been understanding what it takes to make a robot useful in actual ground-handling operations," De Bruijne reflects. "Inside the hold, technical performance is only part of the picture. The equipment also has to fit the turnaround process and be practical for the people using it."
"We tackle that by spending time understanding the operation, building test setups, and learning through physical experiments. Those lessons shape both the hardware and the AI." In an era of rapid AI announcements, focus is a virtue: "The pace of AI development creates opportunities to solve problems that have been difficult for robotics for a long time. It can also tempt you to chase every new development. Keeping the aircraft hold as our focus helps us stay grounded: does this advance help us handle baggage more safely and reliably?"
Safety engineering under the Machinery Directive and the EU AI Act
Deploying multi-axis autonomous machinery inside high-value aircraft cabins demands strict regulatory compliance. "Operating inside an aircraft hold makes safety a central engineering requirement," De Bruijne stresses. "We are developing equipment that moves heavy baggage close to aircraft structures and works as part of an operation involving people. Risk assessment, safety functions, documentation, and validation therefore belong in the development process from the beginning."
The startup is mapping its technical architecture to Europe's evolving regulatory landscape: "The European AI Act takes a risk-based approach. For high-risk systems, these include risk management, documentation, human oversight, and robustness. We are establishing how those requirements apply to our product alongside the relevant machinery and product-safety rules."
"Our aim is to test new capabilities in controlled conditions, define clear operating limits, and ensure the robot can stop safely or request human assistance when it is uncertain. We see that discipline as part of innovation: turning promising AI into a dependable tool that ground handlers can use with confidence."
Eindhoven's mechatronics heritage and the scaling gap
Developing advanced robotic hardware alongside cutting-edge physical AI requires a specialised regional ecosystem. "Brabant is a good place to build the kind of system we are developing," De Bruijne notes. "Around Eindhoven, there is engineering talent, research, a strong supplier network, and experience in turning complex technology into reliable machines. Eindhoven also has a growing AI knowledge base and community, with TU/e and the AI Innovation Center helping researchers, engineers, and entrepreneurs connect and share expertise. Bringing together mechanics, electronics, and AI requires exactly that combination."
Public grants provide crucial breathing space during early development: "National subsidies can make a real difference by helping fund AI development, prototypes, and testing before a product generates revenue. That support can give startups like UNSEQ more room to solve difficult technical problems and turn promising research into practical technology."
However, De Bruijne identifies a familiar European hurdle in hardware commercialisation: "What I would like to see more of is support for the step from a promising prototype to a dependable commercial product: patient capital, accessible testing opportunities, and customers willing to help validate new technology. We need to be as good at scaling technology as we are at inventing it."
The coming wave of physical disruption
On the AI for Good versus AI for Disaster debate, De Bruijne sees embodied artificial intelligence as the next great industrial wave. "AI can be very useful, and that is exactly why it can be so disruptive," he points out. "I believe the AI boom in physical work is still only beginning. In the coming years, we will see robots perform increasingly complex tasks, well beyond vacuuming the living room. That creates opportunities to reduce dangerous and exhausting work, but it also changes jobs and introduces new risks. We need clear responsibility, meaningful human control, and evidence that systems can be trusted with the tasks they are given."
"I am optimistic because we can make deliberate choices about what to build," he adds. "For UNSEQ, that choice starts with taking the physical burden out of baggage handling."
Delivering on the Evoluon stage
When UNSEQ pitches to the jury at the Evoluon on 12 November, De Bruijne plans to keep the narrative grounded in tangible, real-world utility. "I think we have a strong case because the problem, the commercial need, and the benefit are all clear," De Bruijne concludes. "You do not need to be an AI expert to understand why someone lifting heavy bags all day in a cramped aircraft hold deserves a better solution. Making that solution work requires serious engineering, and that is what we are building UNSEQ around."
"We have a focused application, a practical approach, and an international market. And when we say our AI will do the heavy lifting, we mean it quite literally."
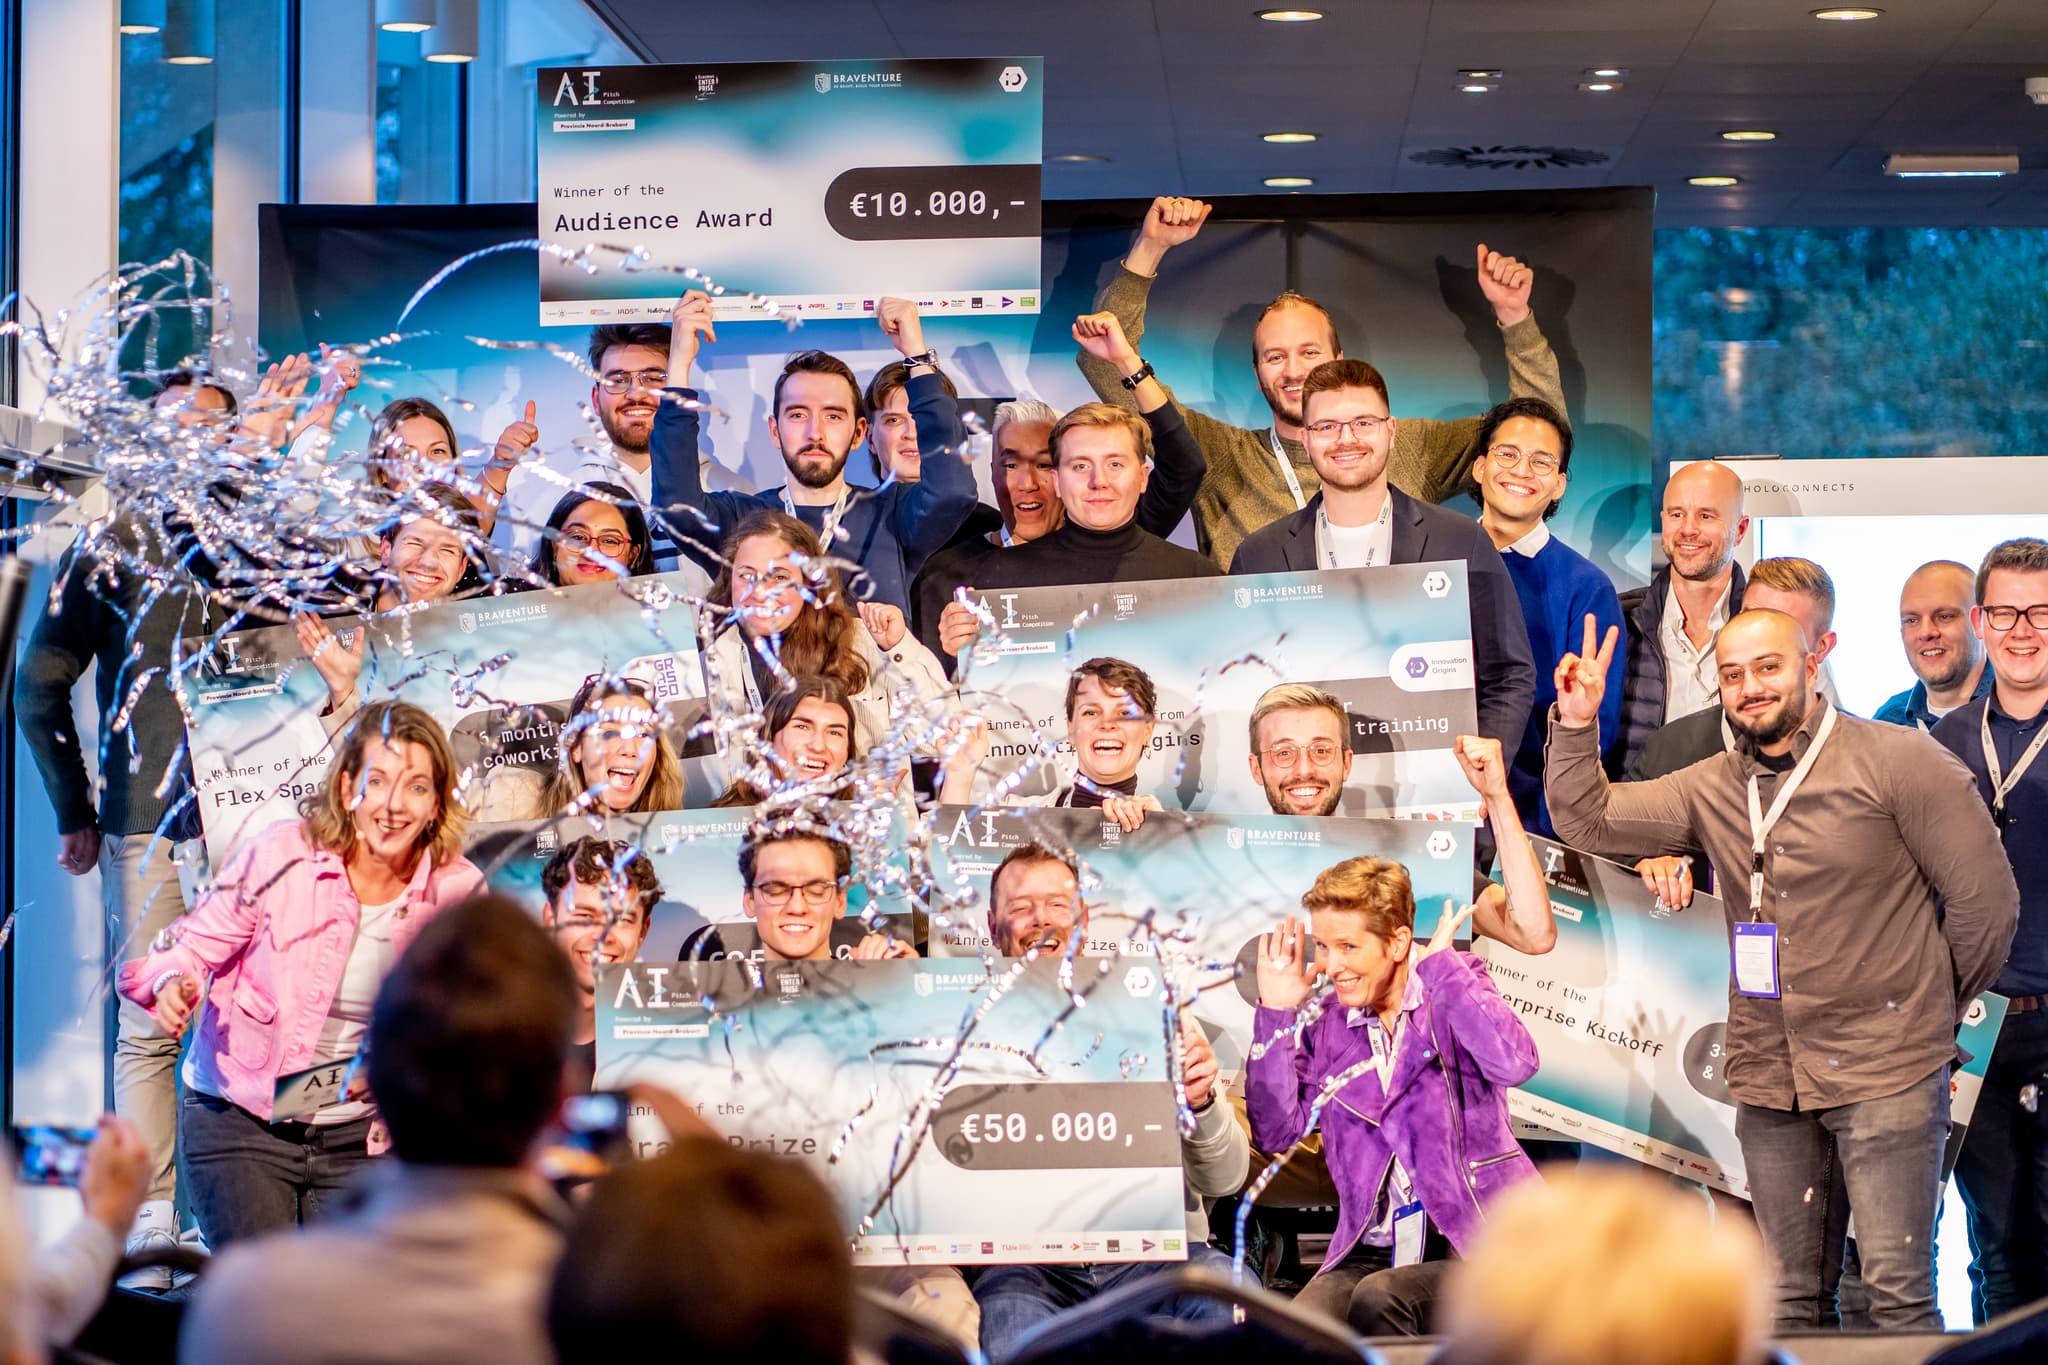
The AI Pitch Competition is organised by Erasmus Enterprise, BOM, and IO+, and supported by the Province of North Brabant. The finals take place during AI Summit Brainport on 12 November at the Evoluon in Eindhoven.